Overview
I designed a foldable electric skateboard with a completely custom battery and motor control solution, while aiming for the smallest, most portable package I had ever seen on an electric skateboard. For the motor controller, I designed a novel power delivery system, a hybrid square/sinusoidal drive, to get unprecedented efficiency without giving up the bottom-end torque you'd expect from 700W combined. Still in progress.
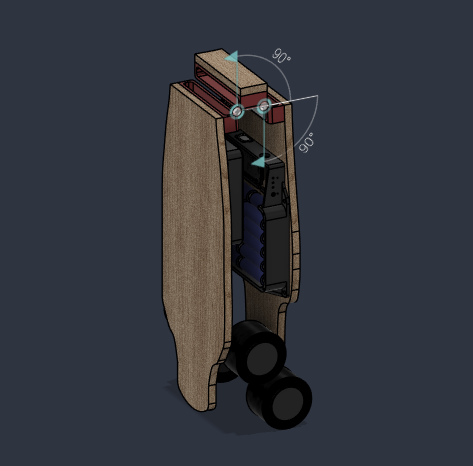
Technical materials
What I learned
- Designed a hybrid square-wave/sinusoidal motor drive that switches commutation modes at an RPM threshold - square-wave for low-speed torque, sinusoidal above it for efficiency - currently a hard cutover, with a blended transition planned as a follow-up
- Built a 10S2P 21700 battery pack from raw cells, paired with a custom BMS designed around TI's BQ77PL900DLR, which handles both cell protection and coulomb-counting fuel gauging in one IC
- Chose JST and XT60 connectors for the battery interface, sized for both current rating and durability through repeated folding and unfolding
- Drove the three-phase motor stage with a dsPIC33CK32MP105 motor-control DSC and hall-effect sensor feedback for commutation, since back-EMF sensing gets unreliable at exactly the low RPMs the square-wave mode is meant to cover
- Diagnosed a short on the first BMS revision caused by leads routed too close together on the board, and fixed it with wider clearance in a respin